
Vignesh Vembar Manikantan
Undergraduate Researcher, Robotics Research Center, IIIT Hyderabad
B.Tech, Electronics & Communication Engineering
I’m Vignesh, an undergraduate researcher at Robotics Research Center, IIIT Hyderabad, advised by Prof. K. Madhava Krishna. My research so far centers around robotic manipulation, in particular bimanual grasping.
In the long term, I’m interested in learning new representations of physical interactions that can help build more capable manipulation policies. I believe the most promising path lies in striking a balance: drawing from the principles underlying human behavior without attempting to replicate every detail of it.
Beyond research, I enjoy listening to music, playing badminton, making 3d art, and playing super long drawn out board games with friends :)
News
- Sep 2026 Submitted Steer2Grasp to ICRA 2027.
- Sep 2026 Our paper PartialBiGrasp was accepted at CoRL 2026!
- Apr 2026 Started as Systems Administrator for the RRC Server Cluster.
- Jan 2026 DAGDiff has been accepted to ICRA 2026 in Vienna 🇦🇹️!
- Jan 2026 Teaching Assistant for Introduction to Robotics: Perception and Planning at IIIT Hyderabad.
- Nov 2025 Placed in the top 15 out of 80+ teams at IN-SPACe CANSAT India 2025.
- Jan 2025 Joined the Robotics Research Center, IIIT Hyderabad as an undergraduate researcher.
Selected Publications
-
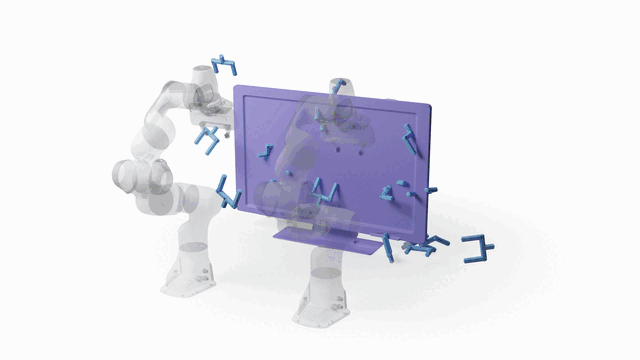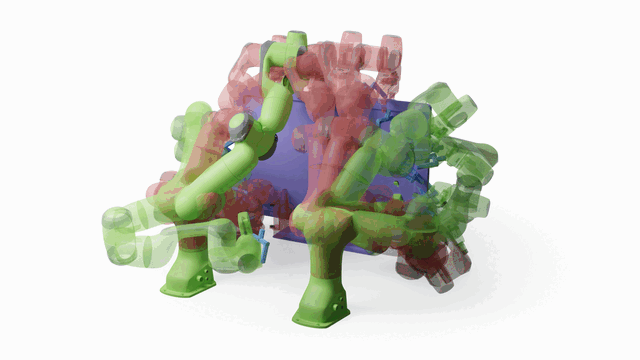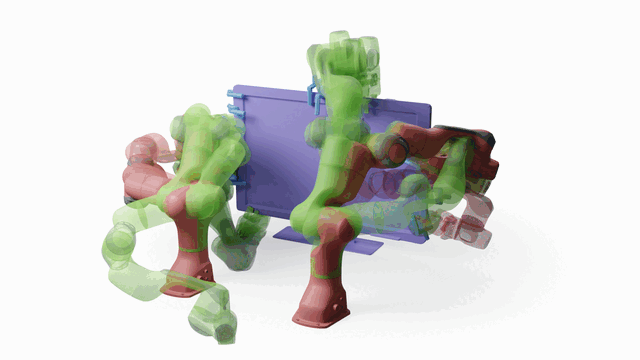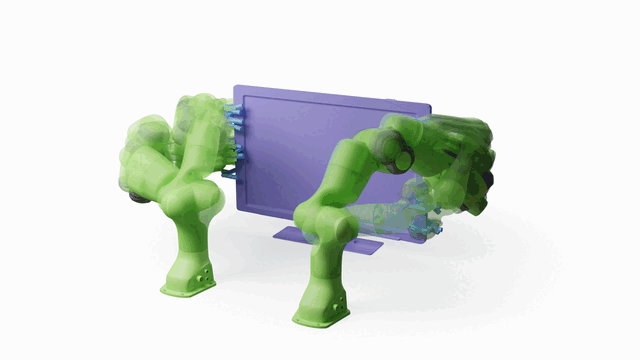 Preprint, 2026 (Under review at ICRA 2027)Embodiment-aware inference-time steering of frozen grasp diffusion models.
-
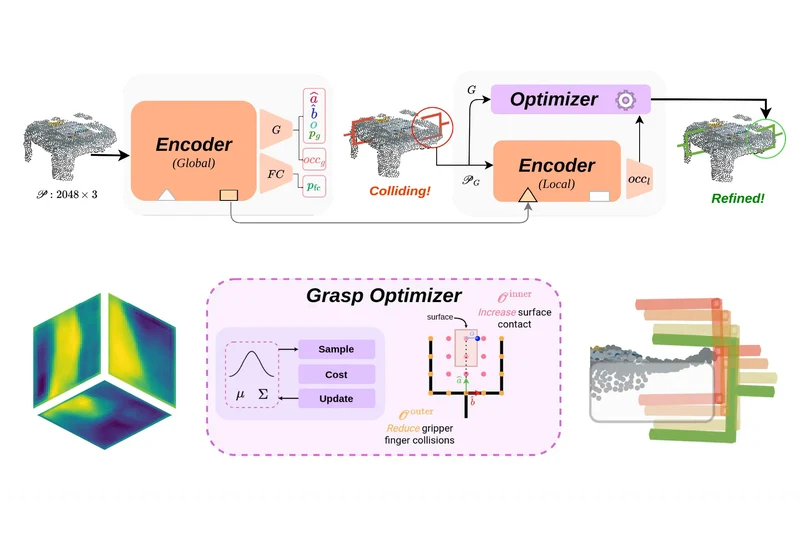 Conference on Robot Learning (CoRL), 2026Dual-arm grasp generation on single-view point clouds, using hierarchical occupancy networks to reason about hidden local geometry.
-
 IEEE International Conference on Robotics and Automation (ICRA), 2026End-to-end diffusion that directly generates dual-arm grasp pairs given a point cloud.